Systems Theory
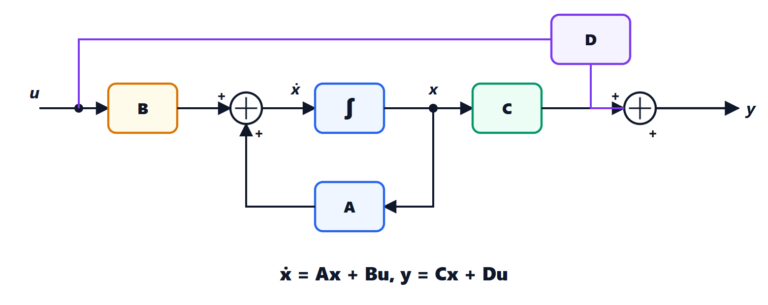
State-space representation, equilibria and linearisation
The concept of state, classification of systems, linear time-invariant systems, an RLC circuit example, equilibrium points, linearisation with proof, the pendulum, changes…
Category
Fourth-year subjects: applied electronics, systems theory, electrical communications, digital electronics, electrical measurements and process control.
82 articles
The concept of state, classification of systems, linear time-invariant systems, an RLC circuit example, equilibrium points, linearisation with proof, the pendulum, changes…
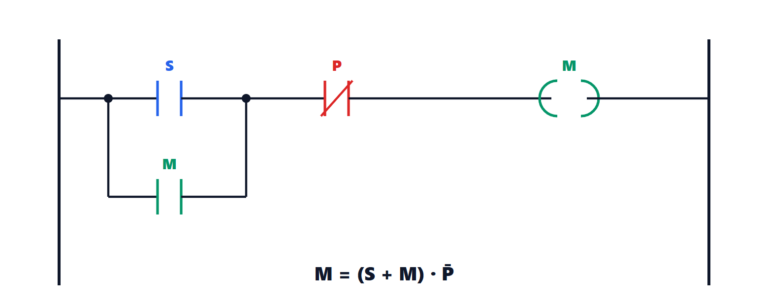
Structure of a PLC, the scan cycle and the response time proved, ladder, FBD, ST and SFC languages, start-stop with seal-in, fail-safe…
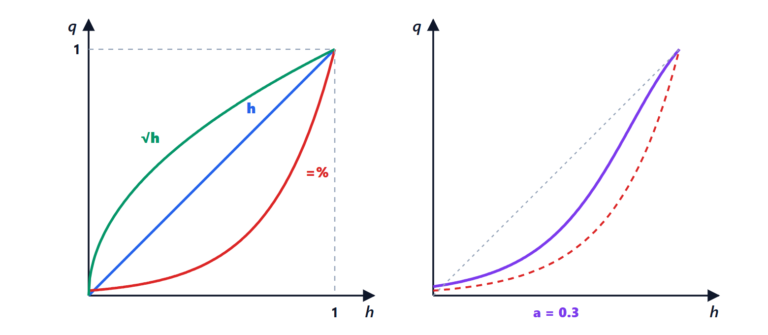
The flow equation and the Kv coefficient, linear and equal-percentage characteristics with proof, the installed characteristic and authority proved, sizing, actuators, positioner,…
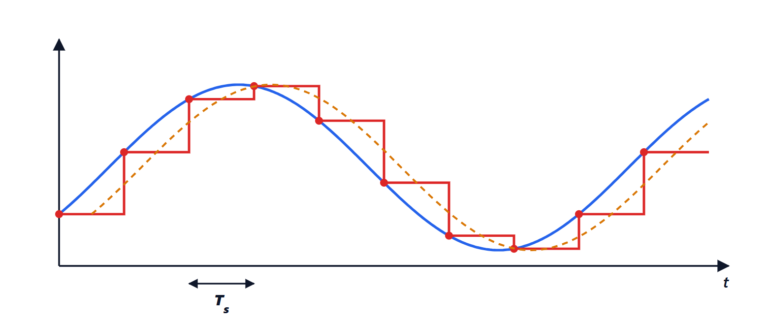
The zero-order hold as a half-period delay with proof, choosing the sampling period, anti-aliasing, the position PID, the velocity form proved, anti-windup…
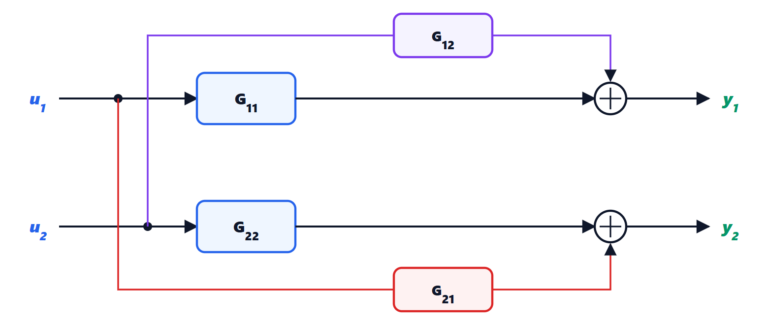
Process with two inputs and two outputs, Bristol's relative gain with proof, rows and columns summing to one, the pairing rule, a…
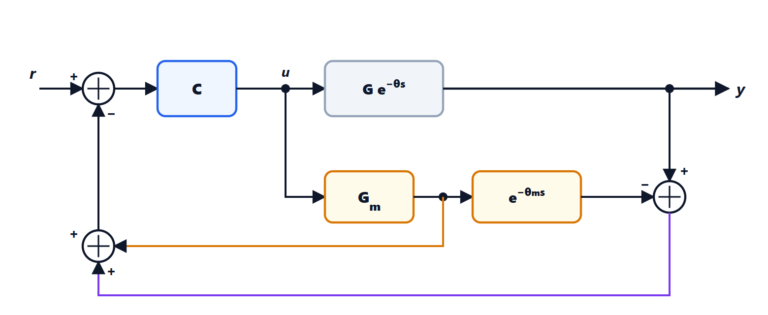
The bandwidth limit imposed by dead time with proof, the Smith predictor with proof, the effect of model errors and disturbances, Padé…
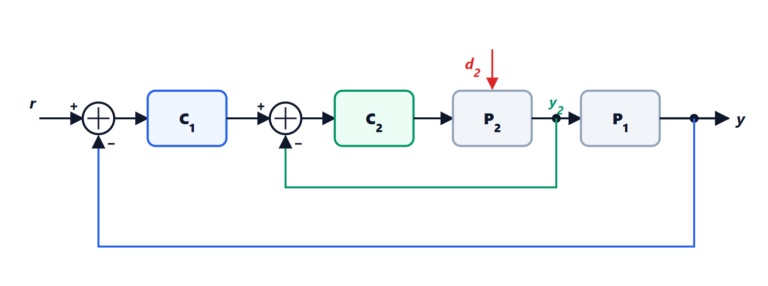
Cascade control with proof of disturbance rejection, feedforward with proof that it does not change stability, realisability, ratio control, split range, selectors…
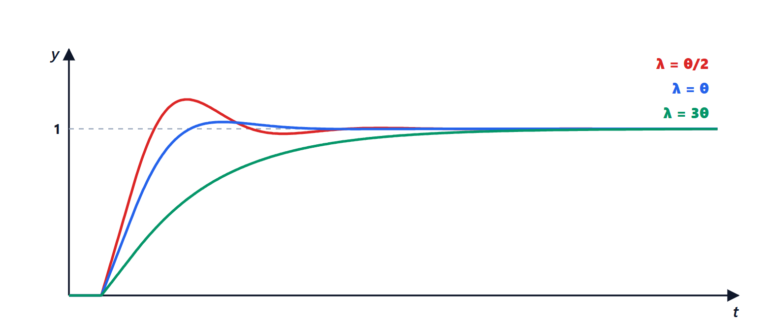
Forms of the industrial PID, direct synthesis for the process with dead time with proof, choosing lambda, the SIMC correction with proof…
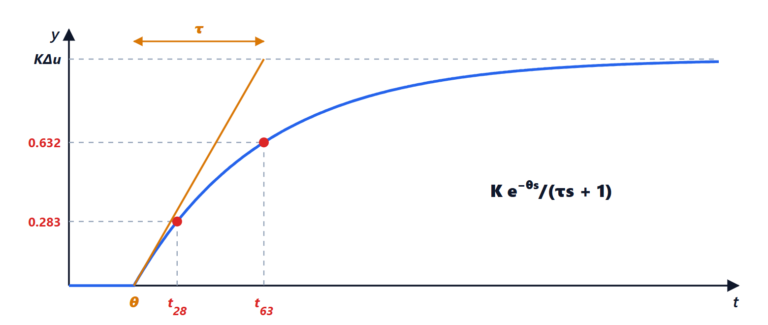
Process variable, manipulated variable and set point, models from mass balances, dead time, the first-order-plus-dead-time model, the two-point method proved, a heat…
The measurement chain, quarter, half and full bridge strain gauges with proof, thermocouples and the cold junction, three- and four-wire Pt100, common…